
 MicroDuck
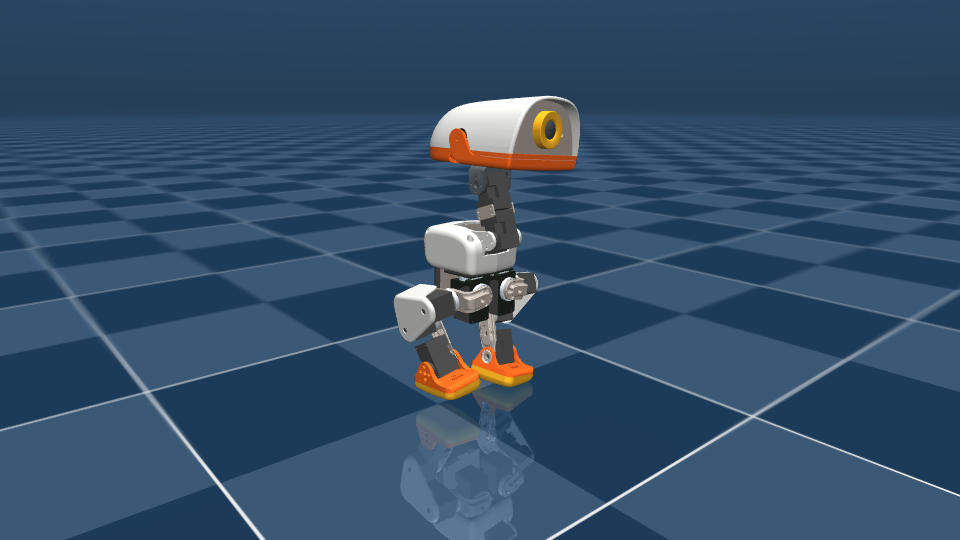
A 25 cm biped with 14 servos, walking under the neural network policy Pollen Robotics trained in MuJoCo.

Components

Complete 14-joint biped plant generated from the training MJCF, with servo-driven links, gear play and eight contact points under each sole.

Rigid body behind a revolute joint, pairing a position servo with 2° of smoothed gear backlash and joint limit stops.

Dynamixel XL330 position servo: identified DC motor, gear play, friction, command delay and an optional thermal model.

Point contact with the soft pyramidal friction cone of MuJoCo, so a policy trained there meets the same ground.

Two-cell lithium-ion pack from the Modelica Standard Library cell stack, for supply sag under walking load.

Neural network walking policy evaluated at 50 Hz with low-pass target filtering, command delay and delayed speed observation.
The MicroDuck series
Why Rebuild a Walking Robot Duck in Modelica?
A flock of 25 cm MicroDuck robots walked out on stage with Jensen Huang at NVIDIA GTC. Pollen Robotics and Hugging Face released the MuJoCo training environment and neural network weights under…
Read post →Working on a robot?
Tell us what you need to understand, predict or control.
Talk to an Expert